Least squares approximations
Lecture 18
Least Squares Approximations
$$ % Colors
% Coordinate vectors and matrices
% Common sets
% Abstract vector symbols
% Norms / absolute value
% Optional: dot product spacing (looks nicer in slides)
% Operators $$
Regression
- In many real-world applications, we want to solve \(A\vec{x}=\vec{b}\), where \(A\) is determined from a mathematical model and \(\vec{b}\) is obtained from experimental or observed data.
- However, the model may not be perfect and the data may contain noise, so the system \(A\vec{x}=\vec{b}\) may have no exact solution.
- In this case, we try to find the best possible \(\vec{x}\) by making \(A\vec{x}\) as close to \(\vec{b}\) as possible.
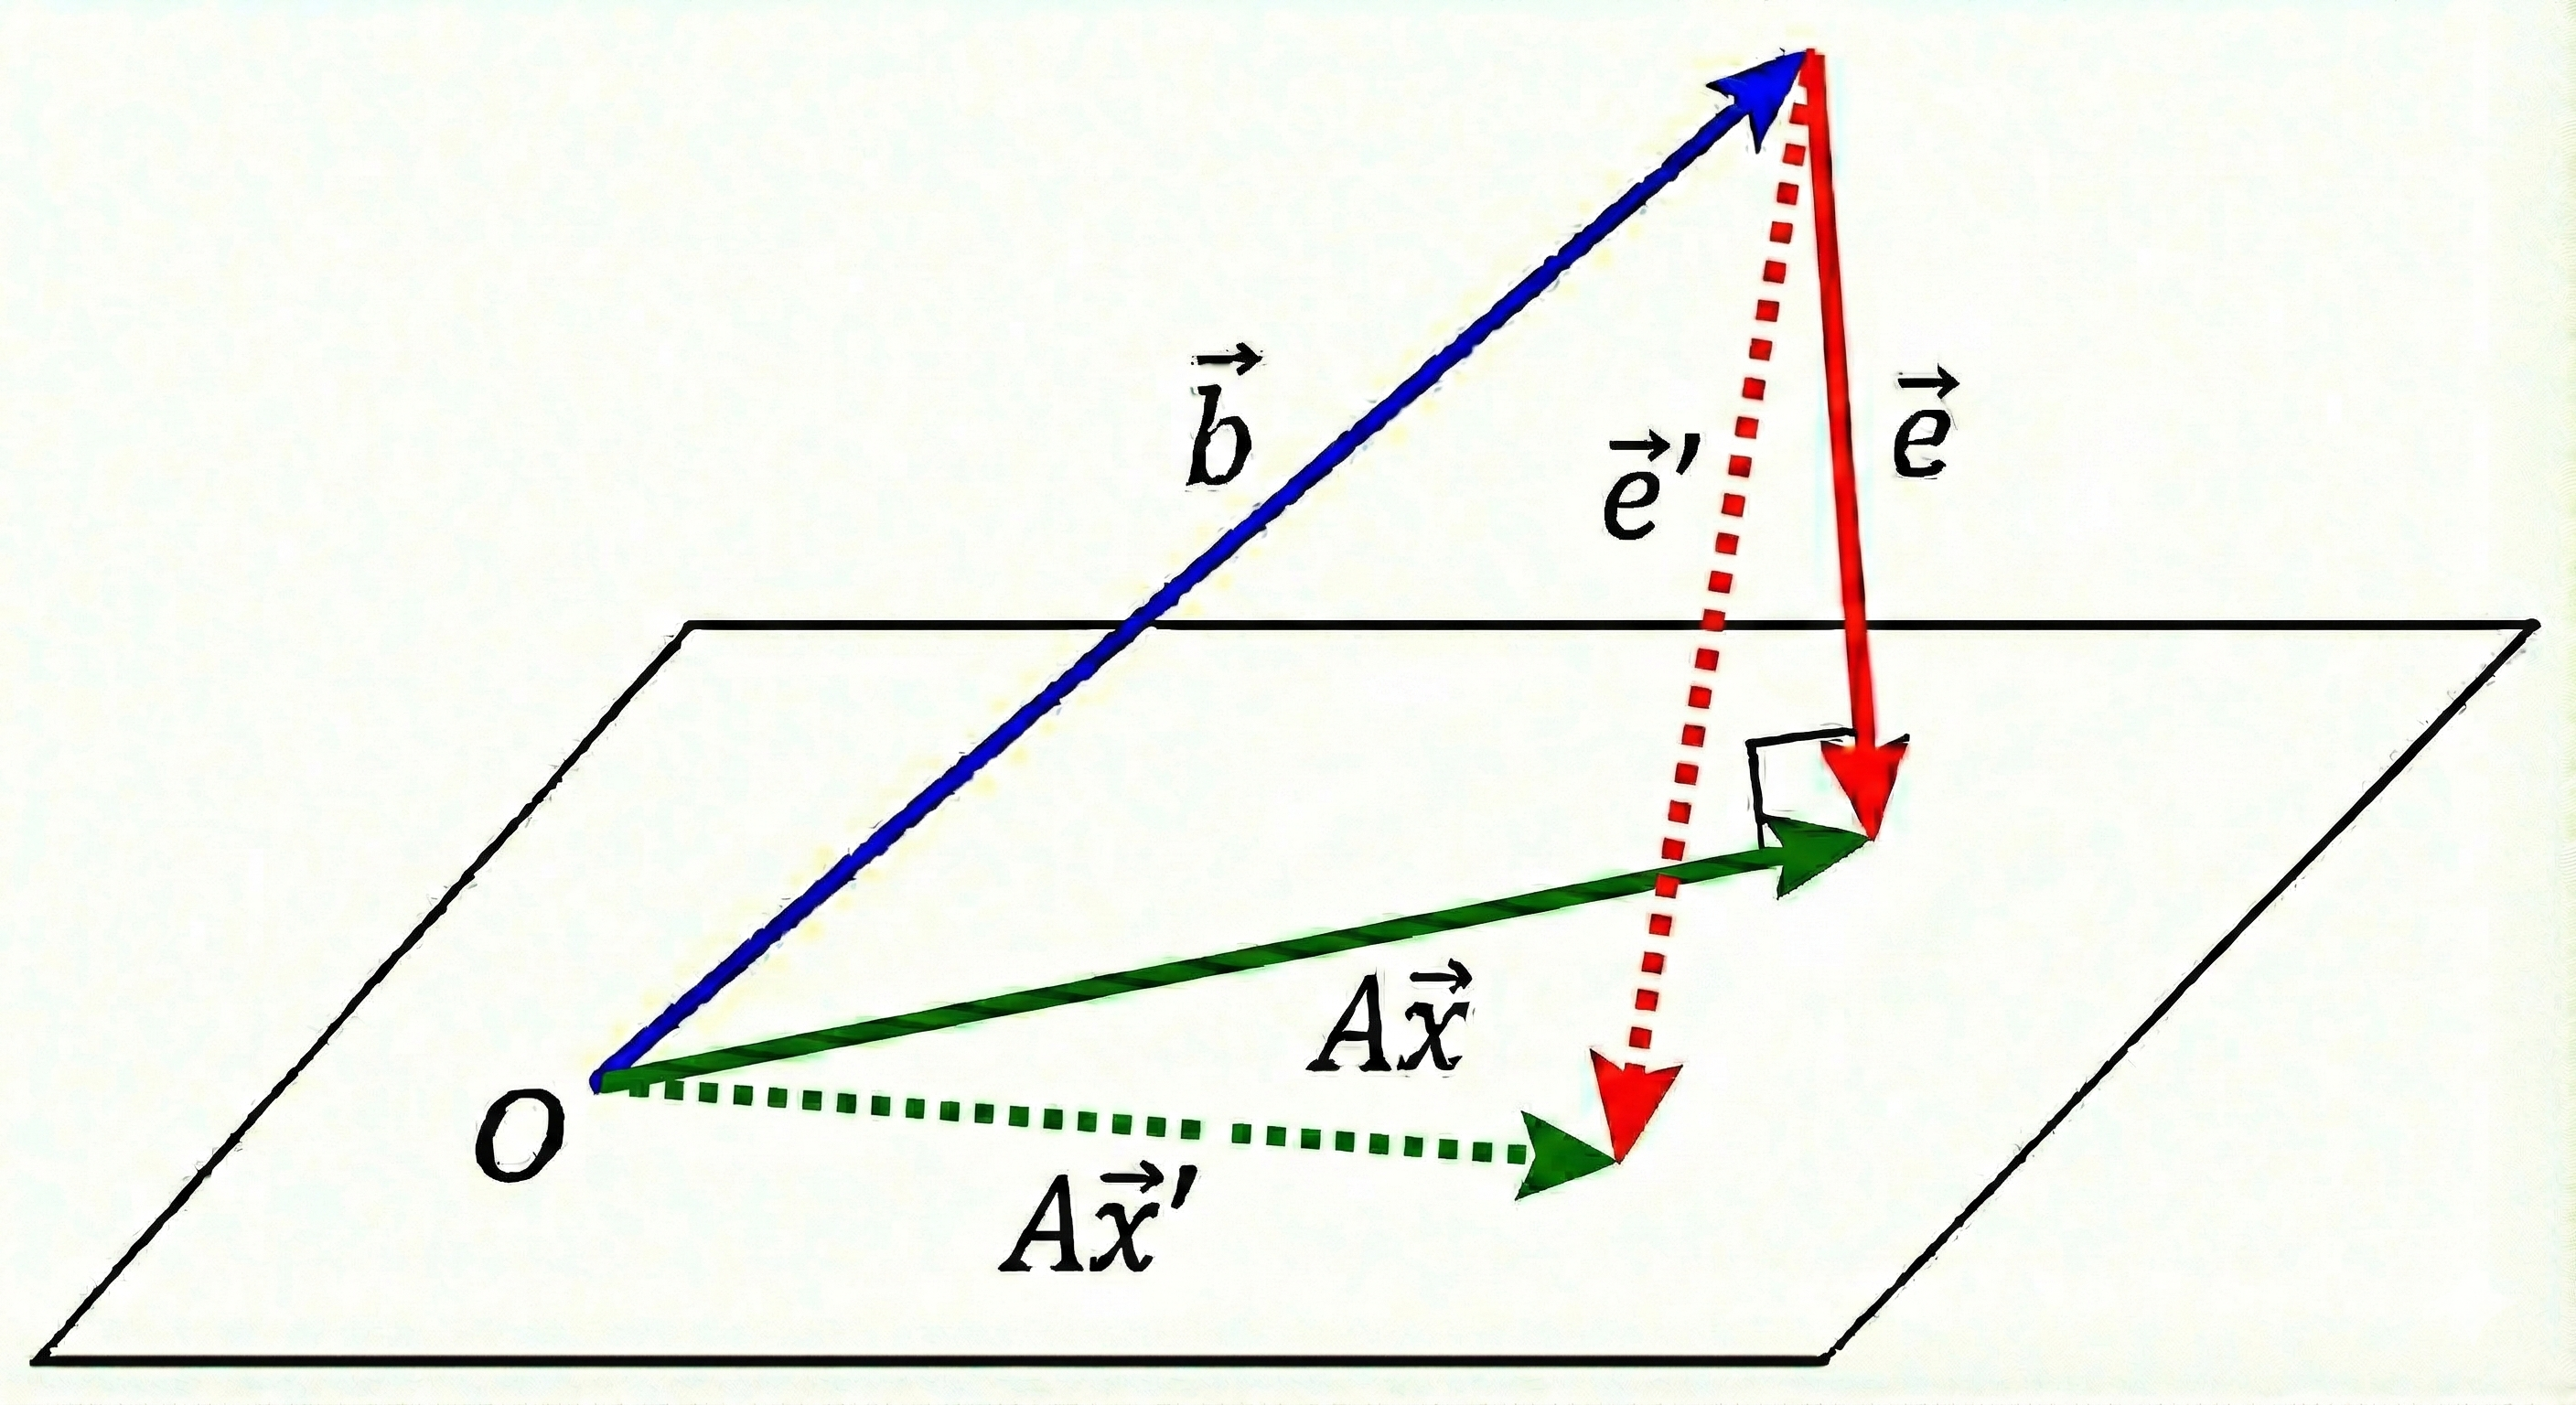
- Define the error vector \(\vec{e} = A\vec{x} - \vec{b}\).
- To measure “closeness,” we minimize the length (Euclidean norm) of the error: \[\left\lVert \vec{e} \right\rVert = \sqrt{\vec{e} \!\cdot\!\vec{e}}.\]
Least Squares Approximation
- Goal: find \(\vec{x}\) such that \(A\vec{x}\) is closest to \(\vec{b}\).
- Geometric intuition: the vectors \(A\vec{x}\) form a subspace \[W = \text{span}\{\vec{u}_1,\dots,\vec{u}_n\},\] where \(\vec{u}_i\) are the columns of \(A\).
- In general, \(\vec{b} \notin W\), so \(A\vec{x}=\vec{b}\) has no solution.
- The best approximation occurs when we project \(\vec{b}\) orthogonally onto \(W\).
- Thus, the least squares solution corresponds to the orthogonal projection of \(\vec{b}\) onto \(W\).
Illustration
Normal Equations
- Let \(A = [\vec{u}_1 \ \dots \ \vec{u}_n]\).
- Recall: \[A^T\vec{v} = \begin{bmatrix} \vec{u}_1 \!\cdot\!\vec{v} \\ \vdots \\ \vec{u}_n \!\cdot\!\vec{v} \end{bmatrix}.\]
- If \(\vec{v}\) is orthogonal to every column \(\vec{u}_i\), then \(A^T\vec{v}=\vec{0}\). In this case, \(\vec{v}\) is orthogonal to the entire subspace \(W = \text{span}\{\vec{u}_1,\dots,\vec{u}_n\}\).
- Thus, for the best approximation, the error \(\vec{e} = A\vec{x}-\vec{b}\) must satisfy \[A^T\vec{e} = 0.\]
Normal Equations (continued)
- Therefore, \[A^T(A\vec{x}-\vec{b})=0,\] which gives the normal equations \[A^TA\vec{x} = A^T\vec{b}.\]
- Geometrically, this system always has a solution (when columns of \(A\) are linearly independent).
Exercise
- Let \[ A=\begin{bmatrix} 1 & 2 \\ 1 & \tfrac{3}{2} \\ 1 & 4 \end{bmatrix}, \qquad \vec{b}=\begin{bmatrix}1\\2\\1\end{bmatrix}. \]
- Describe in words the geometric meaning of the least squares approximation to \(A\vec{x} \approx \vec{b}\).
- Compute the best approximation \(\vec{x}\) by solving the normal equations.
Example 9 from Larson’s Book
The table shows the world population (in billions) for six different years (Source: U.S. Census Bureau).
| Year | 1985 | 1990 | 1995 | 2000 | 2005 | 2010 |
|---|---|---|---|---|---|---|
| Population | 4.9 | 5.3 | 5.7 | 6.1 | 6.5 | 6.9 |
Let \(x=5\) represent the year 1985 (so \(x=10\) is 1990, etc.).
- We seek a quadratic model \[y=c_0+c_1x+c_2x^2.\]
- Solve the normal equations: \[A^TA\vec{c} = A^T\vec{b}.\]
Example 10 from Larson’s Book
The table shows the mean distances \(x\) (in astronomical units) and orbital periods \(y\) (in years) of six planets closest to the Sun.
| Planet | Mercury | Venus | Earth | Mars | Jupiter | Saturn |
|---|---|---|---|---|---|---|
| Distance \(x\) | 0.387 | 0.723 | 1.000 | 1.524 | 5.203 | 9.537 |
| Period \(y\) | 0.241 | 0.615 | 1.000 | 1.881 | 11.862 | 29.457 |
- We expect a power model of the form \(y = Cx^k\).
- Take logarithms: \(\ln y = \ln C + k \ln x\).
- This becomes a linear regression problem in variables \(Y=\ln y, \quad X=\ln x\).
- Use least squares to determine \(\ln C\) and \(k\).
- Result relates to Kepler’s Third Law: \(y^2 \propto x^3\).
Fourier Approximations
Fourier Series
- In signal processing, it is useful to decompose a signal into different frequency components.
- Let \(f:[0,2\pi]\to\mathbb R\) be continuous.
- A Fourier series representation is \[ f(x)=\frac{a_0}{2}+\sum_{n=1}^{\infty}\big(a_n\cos(nx)+b_n\sin(nx)\big). \]
- Interpretation:
- \(f\) is written as a linear combination of \(\{1,\cos x,\cos 2x,\dots,\sin x,\sin 2x,\dots\}\).
- Each \(\cos(nx)\) and \(\sin(nx)\) represents the \(n\)th frequency mode.
- The coefficients \(a_n,b_n\) represent amplitudes.
Trigonometric Functions
- Consider the inner product on \(C([0,2\pi])\): \[\left\langle f,g \right\rangle=\int_0^{2\pi} f(x)g(x)\,dx.\]
- Orthogonality relations: \[ \int_0^{2\pi}\cos(ix)\cos(jx)\,dx= \begin{cases} \pi & i=j\neq0 \\ 2\pi & i=j=0 \\ 0 & i\ne j \end{cases} \] \[ \int_0^{2\pi}\sin(ix)\sin(jx)\,dx= \begin{cases} \pi & i=j \\ 0 & i\ne j \end{cases} \] \[ \int_0^{2\pi}\cos(ix)\sin(jx)\,dx=0 \quad \text{for all } i,j. \]
Orthonormal Trigonometric Basis
- Theorem: any continuous function can be represented uniquely by its Fourier series.
- After normalization, the set \[ S=\left\{\frac{1}{\sqrt{2\pi}},\frac{\cos(nx)}{\sqrt{\pi}},\frac{\sin(nx)}{\sqrt{\pi}}:n\ge1\right\} \] is an orthonormal basis of \(C([0,2\pi])\).
Example: Equalizer in Music
- A musical sound wave is a superposition of many different frequencies produced by instruments and voices. 🎥Visualization
- Each frequency band corresponds to a certain instrument, tone color, or vocal range (bass, mid, treble).
- Using a Fourier decomposition, the sound signal can be written as a sum of frequency modes with different amplitudes.
- An equalizer adjusts the amplitudes of selected frequency modes to enhance or suppress certain components.
- For example, we can boost low frequencies (bass), reduce harsh high frequencies, or emphasize vocal ranges.
- The same idea is used in noise-canceling: suppress unwanted frequency bands (e.g., airplane engine noise) while preserving or amplifying human speech.
Example: Image Processing
- A digital image can also be viewed as a “signal,” where the pixel values represent function values.
- Smooth regions in an image correspond to low-frequency components, while rapid changes in intensity correspond to high-frequency components.
- By enhancing high-frequency components, we can make edges more visible (edge detection).
- By suppressing high-frequency components, we can smooth the image (blur or noise reduction).
- Early image-processing tools (including older Photoshop techniques such as skin retouching) relied on this frequency separation idea.
- 📰 What are Filtering in Frequency Domain and Fourier Transform?
Fourier Coefficients
- Recall \(f(x)=\frac{a_0}{2}+\sum_{n=1}^{\infty}\big(a_n\cos(nx)+b_n\sin(nx)\big)\).
- Using orthogonality: \[ a_n=\left\langle f,\frac{1}{\pi}\cos(nx) \right\rangle = \frac{1}{\pi}\int_0^{2\pi} f(x)\cos(nx)\,dx,\quad n\ge1, \] \[ b_n=\left\langle f,\frac{1}{\pi}\sin(nx) \right\rangle = \frac{1}{\pi}\int_0^{2\pi} f(x)\sin(nx)\,dx,\quad n\ge1, \] \[ a_0=2\left\langle f,\frac{1}{2\pi} \right\rangle = \frac{1}{\pi}\int_0^{2\pi} f(x)\,dx. \]
- These are called the Fourier coefficients.
Fourier Approximation
- In practice, we cannot compute or store infinitely many Fourier coefficients.
- Fortunately, most of the essential (global) features of a function are captured by low-frequency modes, while high-frequency modes often encode fine details or noise.
- We approximate \(f\) by truncating its Fourier series: \[ f(x)\approx \frac{a_0}{2}+\sum_{n=1}^{N}\big(a_n\cos(nx)+b_n\sin(nx)\big). \]
- This truncated series is the orthogonal projection of \(f\) onto the finite-dimensional subspace \[ \text{span}\{1,\cos x,\dots,\cos(Nx),\sin x,\dots,\sin(Nx)\}. \]
Summary
- In many real-world applications, mathematical models are imperfect because we ignore noise or cannot include all possible parameters.
- When fitting parameters in a regression problem \(A\vec{x} \approx \vec{b}\), we use least squares approximation, which minimizes the size of the error vector.
- The least squares solution satisfies the normal equations \[ A^TA\vec{x} = A^T\vec{b}. \]
- Fourier approximation is a special case of least squares approximation, where the “size” of the error is measured using an inner product for functions.
- In particular, a truncated Fourier series is the orthogonal projection of a continuous function onto the vector space spanned by low-frequency trigonometric basis functions.